A Flying Robot Lighter Than a Paperclip Landed on a Sunflower Without Lab Cameras
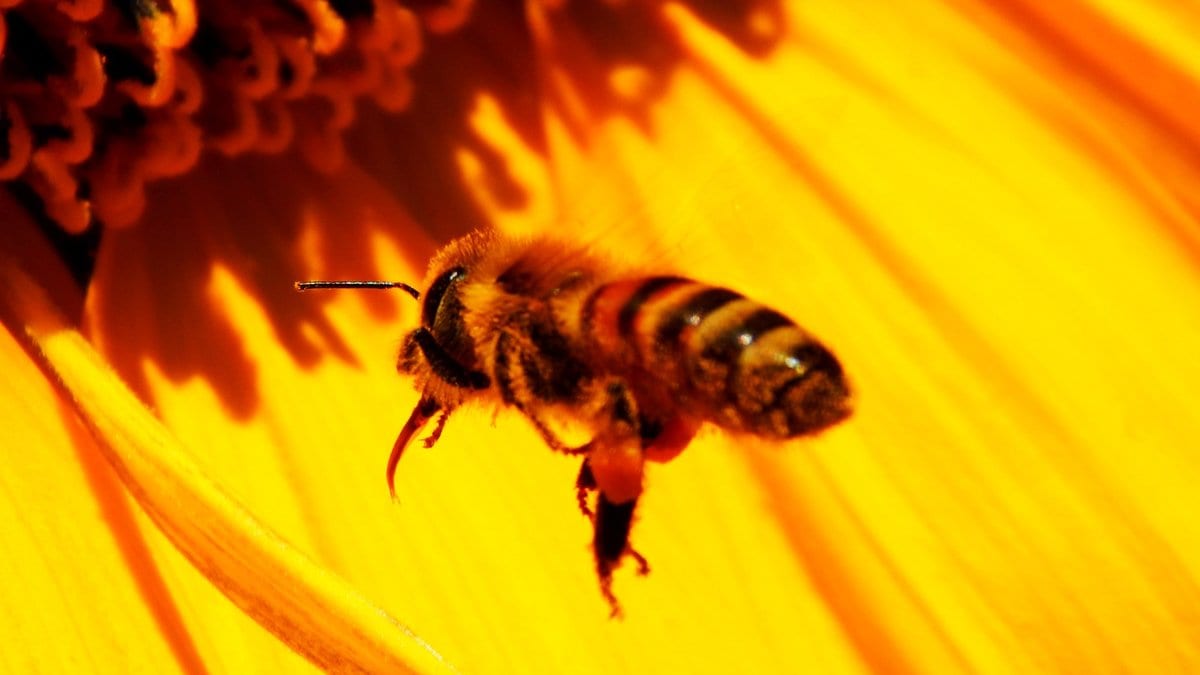
MIT researchers have flown a four-winged robot lighter than a paperclip along a set path and landed it on a sunflower, using position sensors and a processor carried on the robot itself.
Earlier versions of the machine could not lift those electronics and had to stay inside the laboratory's motion-capture volume, a rig of cameras that watched the robot and told it where it was. MIT's release presents the new flights as a step toward precision agriculture, and Kevin Chen, an MIT associate professor and a co-corresponding author, names pollination and industrial surveillance as tasks where a larger robot cannot be used. Those are uses the group is aiming at; the robot is still tethered to a power source on the ground.
MIT says the research appeared Nov. 18, 2026, in Science Robotics. The team tuned the radius and length of the artificial muscles that flap the wings, making them 50% larger while raising the robot's net lift forces by 46%. That brought the lift-to-weight ratio to 1.9, enough to carry a 244-milligram electronics package.
The package holds a unit that tracks the robot's tilt, an optical sensor that reads its sideways drift, a sensor that times a light pulse to measure height, and a microcontroller. The team also simplified the position calculation, and found a faster continuous estimate worked better than a slower, more accurate one. Co-lead author Yi-Hsuan Hsiao, an MIT graduate student, says: "Our robot can now fly with positional accuracy that is comparable to flying with offboard cameras."
In the demonstrations, the robot hovered at several heights and flew point-to-point trajectories, with positional errors MIT's release puts at only a few centimeters. An operator guided it around several plants with a joystick, sending high-level position targets, before it landed on the sunflower.
MIT reports the electronics draw about 6% of the robot's total power, the rest going to the muscles and wings. The group says its next steps are an onboard camera, for recognizing objects and avoiding obstacles, and power electronics and batteries of its own, for untethered outdoor flight.
Sources
- news.mit.edu
- Science RoboticsPeer-reviewed